

 A matrix has four entries, so you can think of it as a single point in . Most of those points are not rotations. A rotation matrix must satisfy three constraints: each column has unit length (two constraints), and the two columns are orthogonal (one more). Four numbers minus three constraints leaves one degree of freedom, the angle .
As changes, moves through and traces a curve. That curve is . It is a one-dimensional manifold living inside a four-dimensional space. In this section you build the curve numerically, find out what shape it is, and see how a velocity along it gives an element of .
Background on Lie groups and their algebras
Rigid-body configurations are encoded by 4×4 homogeneous transformation matrices. Rotation matrices represent orientation. Six-dimensional twists describe spatial velocities. Six-dimensional wrenches represent spatial forces. The table lists the spaces used in rigid-body motion representations, with the notation of Lynch and Park (Kevin M. Lynch, 2017).
and are Lie groups, the curved spaces where configurations live. and are their Lie algebras, the flat tangent spaces at the identity where velocities live. The matrix exponential maps a velocity to a configuration: and . The matrix logarithm goes the other way, from a configuration to a velocity that produces it in unit time: and . The exponential is many-to-one: in the plane, the angles and give the same rotation, so a rotation has many logarithms. Choosing a branch makes the logarithm a function, and the usual choice is the principal angle in . On that branch the logarithm inverts the exponential. The operator turns a vector in or into its matrix form in or .
This section studies the first two rows of the table, and . They are small enough that you can compute and draw everything about them.
Sampling the curve
Each sample of gives one rotation matrix. Flattening the matrix row by row gives its point in , with coordinates .The shape of the curve
The four coordinates of are . Two of them repeat the other two: and . These two linear relations confine the curve to a two-dimensional plane inside . Within that plane, the remaining constraint is the equation of a circle. So is a circle. Its distance from the origin of is the Frobenius norm of , which is for every rotation. The curve is also closed: and give the same matrix, so walking once around brings you back to where you started.Drawing the curve
You cannot draw , but for rotations you do not need to. Because always equals , dropping it loses no information. The plot below uses the three coordinates , and the color shows the angle . The curve is a tilted circle centered on the origin.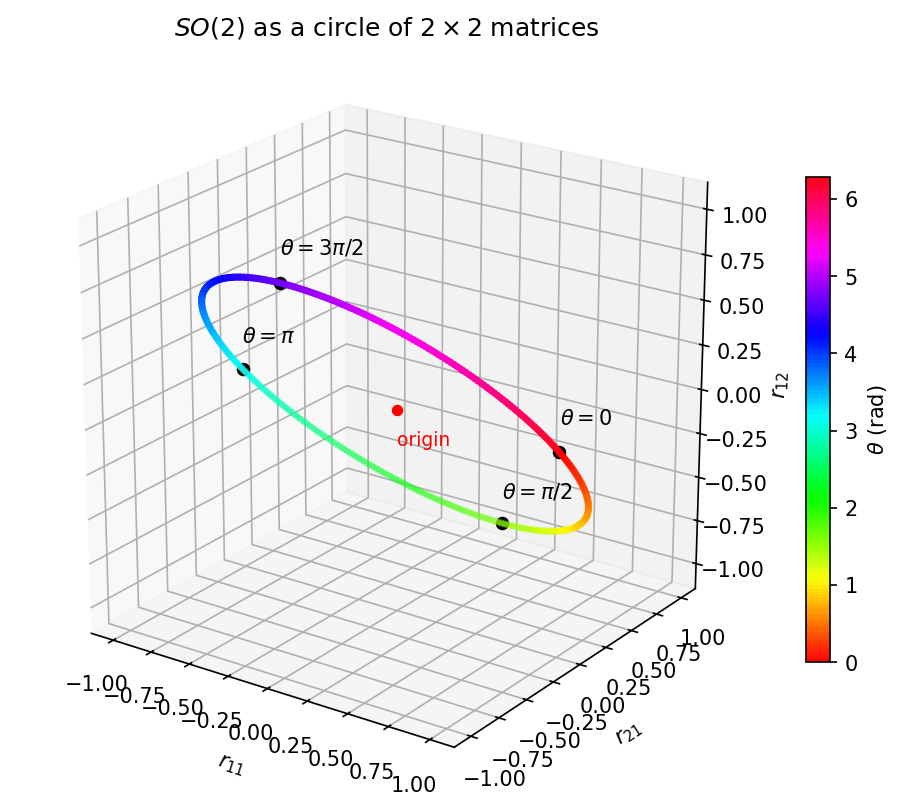
The determinant as signed area
The unit square has corners , , and . Its sides are the basis vectors and , and its area is 1. A matrix sends to its first column and to its second column, so it turns the unit square into the parallelogram spanned by its two columns. For that parallelogram has signed area , which is . Because the square started with area 1, the determinant is the factor by which the matrix scales area. The same factor applies to every region, since any region can be tiled with small squares. The sign records orientation. Walking around the unit square from to is a counterclockwise turn. If the image of is still counterclockwise from the image of , the determinant is positive. If the matrix flips the square over like a mirror, that turn becomes clockwise and the determinant is negative. A determinant of zero means the square is flattened onto a line and the matrix cannot be undone. The determinant is not a measure of how large a matrix is. stretches one direction by a factor of 3, yet its determinant is 1, because the squeeze in the other direction cancels the stretch in area. How far a matrix can stretch a vector is measured by its norm or its singular values instead.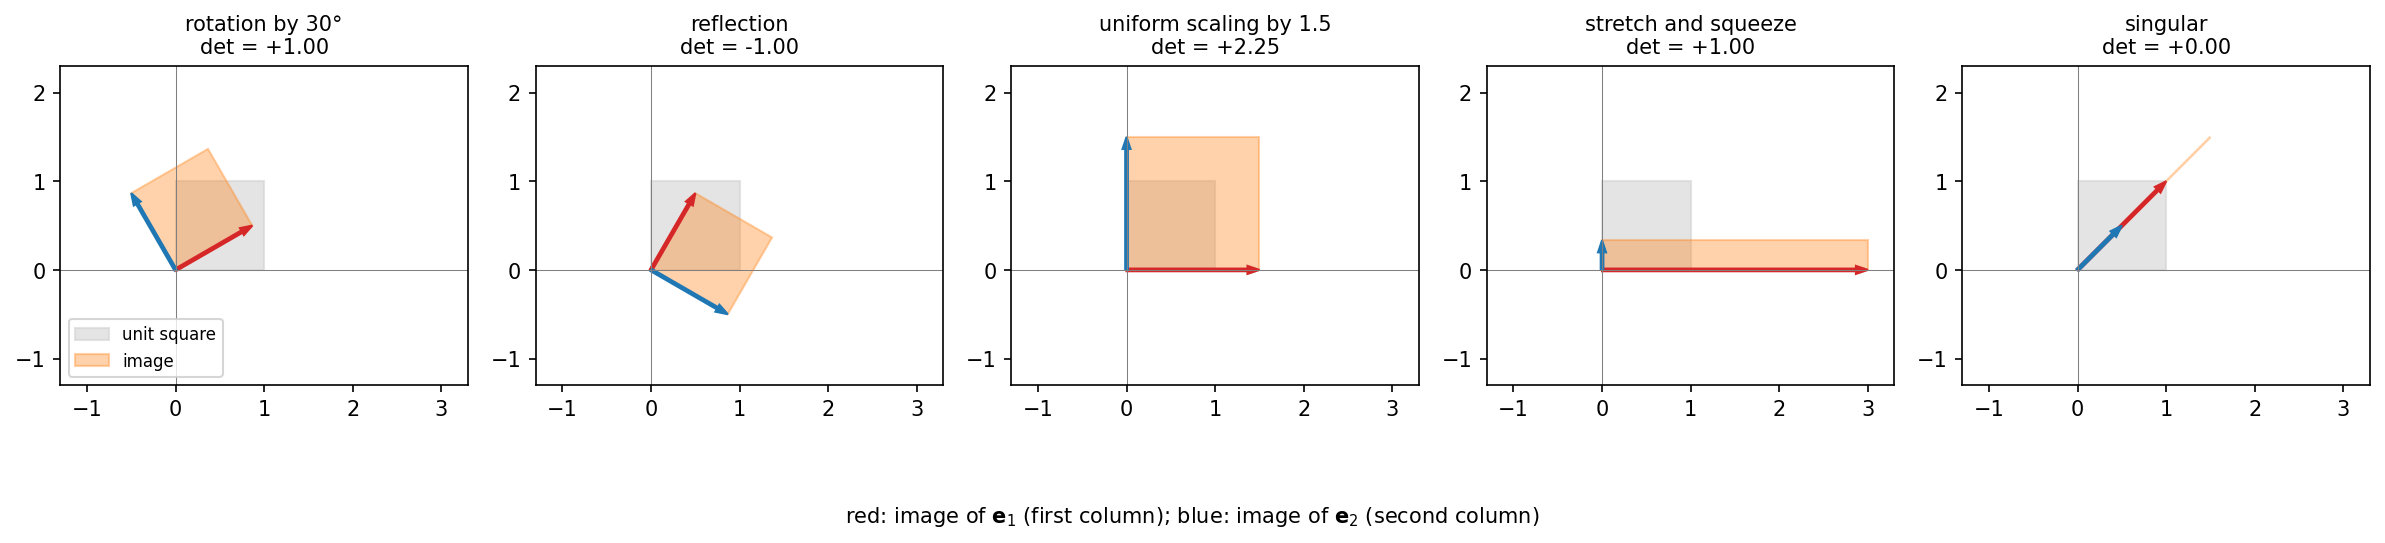
Rotations and reflections
Orthonormal columns alone do not make a rotation. The matrices also have orthonormal columns, but . Each one is a reflection across a line through the origin. As changes, they trace a second circle in . Together the two circles make up , the group of all orthogonal matrices, and the condition selects the circle that contains the identity. No continuous path of orthogonal matrices can turn a rotation into a reflection, because would have to jump from to . So is a manifold in its own right, not just half of . The code below confirms that every rotation is at exactly the same distance, 2, from every reflection.Seeing both circles
The coordinates hide the geometry. A better set of axes for comes from the relations each family satisfies: These four axes are orthonormal, so they describe the same space with no distortion. A rotation has and lands at . A reflection has and lands at . So splits into two perpendicular planes. The rotations fill a circle of radius in the plane, and the reflections fill a circle of the same radius in the plane. Each circle collapses to the origin of the other plane. That also explains the constant distance: any rotation is from the origin in one plane, any reflection is from the origin in the perpendicular plane, and by Pythagoras they are apart.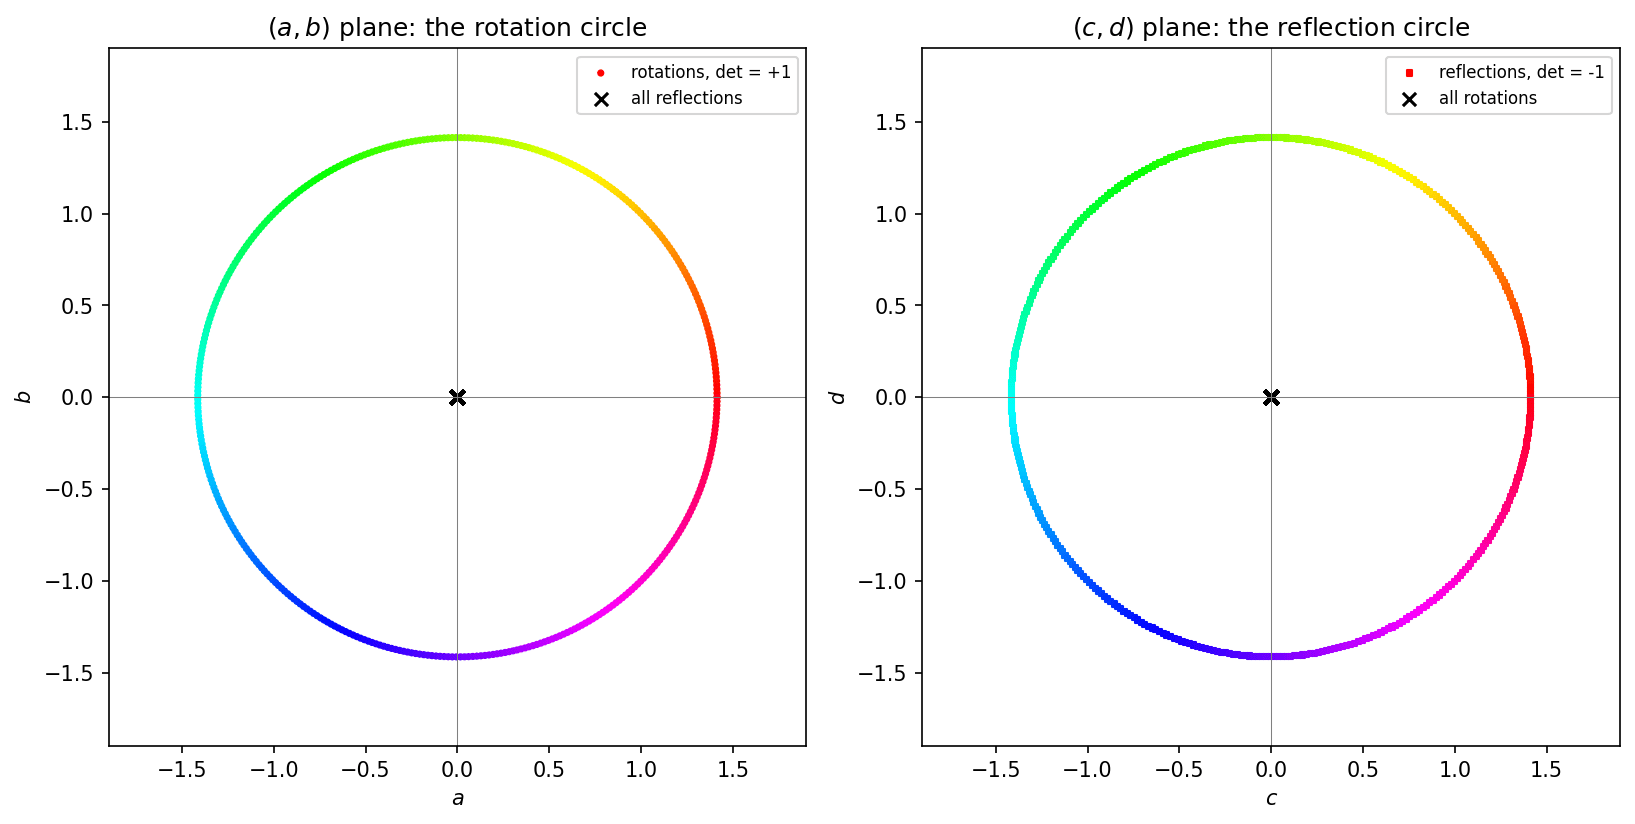
One column is enough
The first column of is where the rotation sends the unit vector . It is the point on the unit circle of the plane. Once you know the first column, orthogonality and fix the second: it is the first column turned by counterclockwise. So every rotation corresponds to exactly one point on the unit circle, and every point on the unit circle to exactly one rotation. This is the precise sense in which is a circle. The top panel follows the first column as grows. The row below shows the full rotated frame at each of the same angles.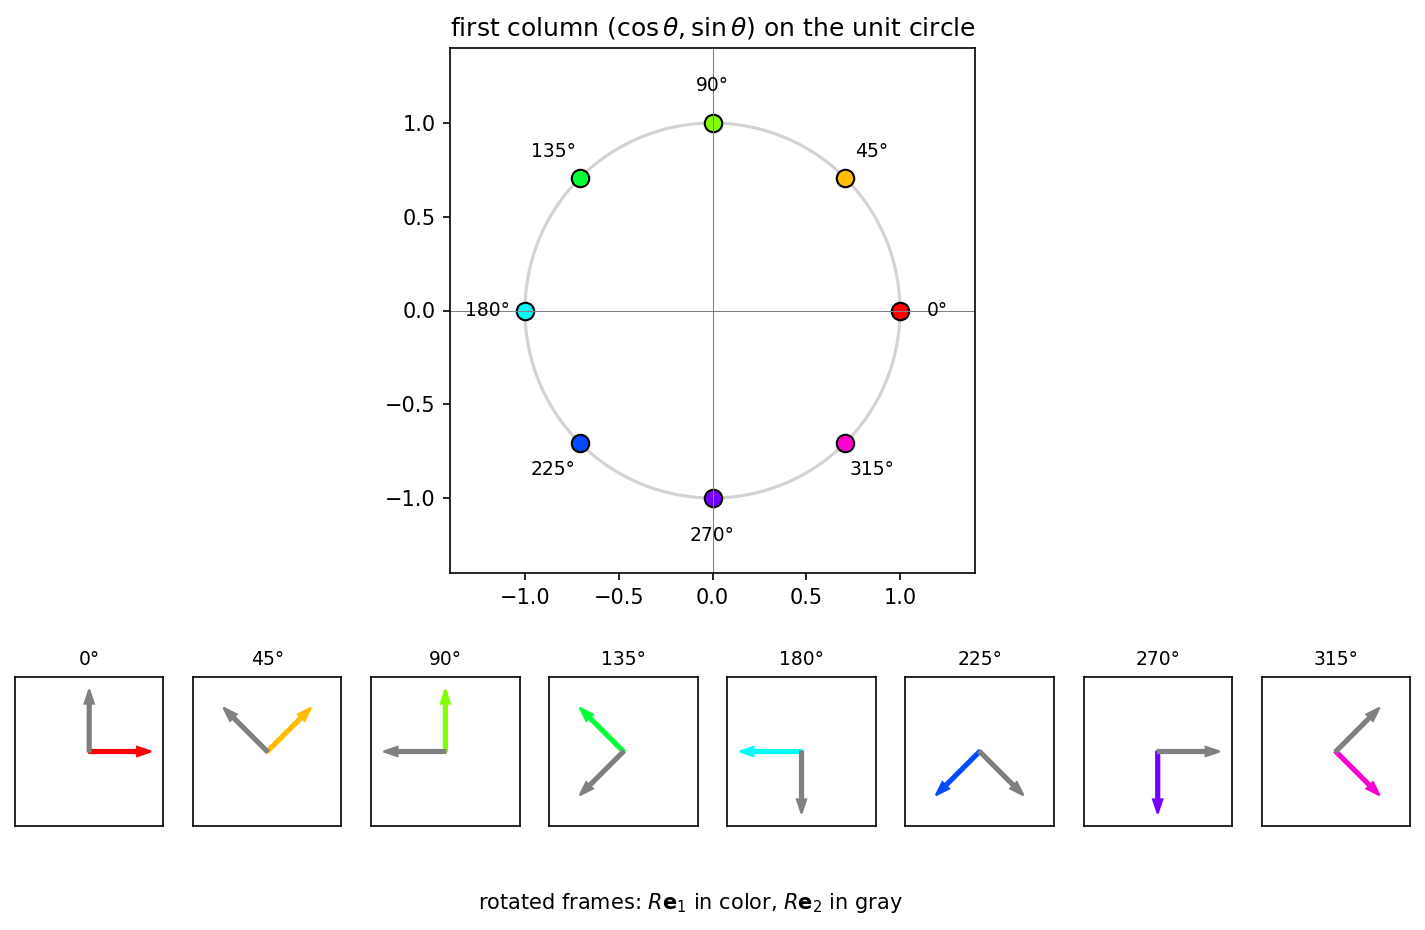
The tangent at the identity
A one-dimensional manifold looks like a straight line when you zoom in close enough. At the identity (), that line is the tangent to the curve. Its direction is the derivative of at : This is a skew-symmetric matrix, an element of . Scaling it by an angular rate gives every possible velocity at the identity, so is one-dimensional, just like . The matrix exponential maps back onto the curve: exponentiating times this tangent matrix reproduces .References
- Kevin M. Lynch, F. (2017). Modern Robotics.
- (n.d.). The Matrix Cookbook.